A Study on Autonomous UAV Take-off and Landing on a Carrier
7th Asia-Pacific International Symposium on Aerospace Technology (APISAT), Cairns, Australia, Nov. 2015
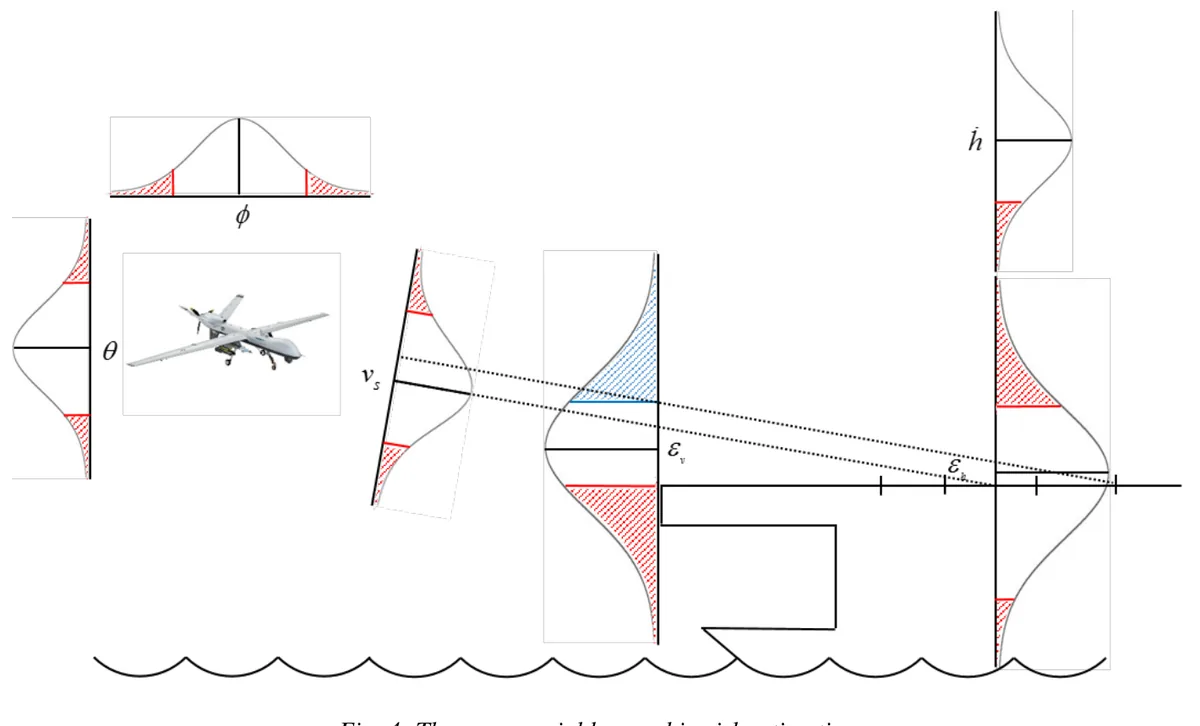
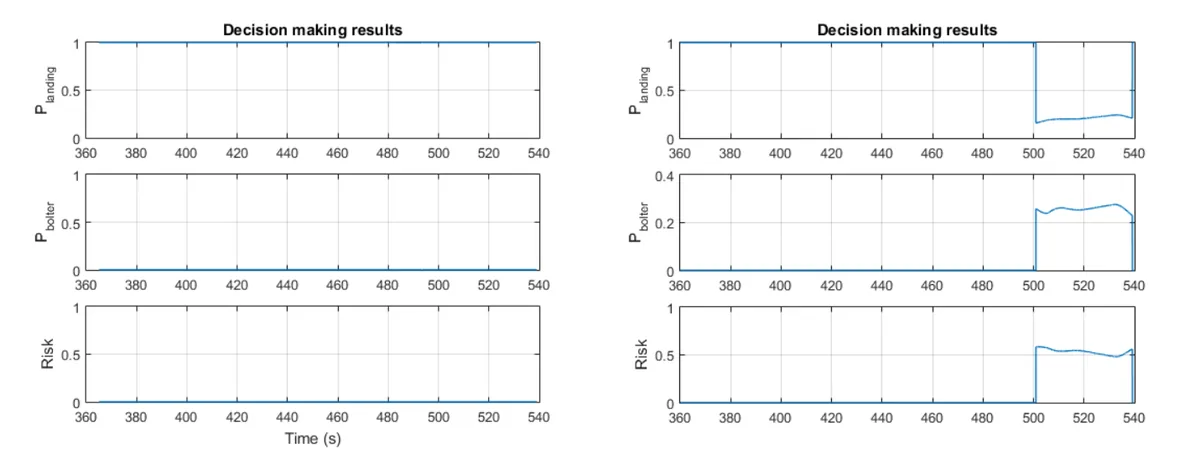
Figures and captions reproduced from the paper (© the authors and original publisher).
Landing on an aircraft carrier is one of the most challenging issues for Unmanned Aerial Vehicles (UAVs) because position and velocity of the landing site change as the aircraft carrier continuously moves on the sea. In addition, uncertain parameters such as winds and heights of the waves make the automatic landing/take-off problem more difficult. This study proposes an Automatic Carrier Landing System (ACLS) for UAVs including decision making process as well as guidance and control. The problem considered in this study is composed of three phases: take-off, approach, and landing. Suitable guidance and control laws are designed for each phase. Decision making logic is also developed based on the stochastic risk evaluation scheme. Numerical simulation results demonstrate the performance of the proposed decision making logic and guidance and control laws.
https://jihoonlee91.github.io/papers/pdfs/2015-autonomous-uav-takeoff-landing-carrier.pdfBibTeX@inproceedings{Lee2015,
title = {A Study on Autonomous UAV Take-off and Landing on a Carrier},
author = {Somang Lee and Jihoon Lee and Seokwon Lee and Youdan Kim and Jinyoung Suk and Seungkeun Kim},
year = {2015},
booktitle = {7th Asia-Pacific International Symposium on Aerospace Technology (APISAT), Cairns, Australia, Nov. 2015},
}