A Decision Making Technique for UAV Automatic Carrier Landing System
Published in Korean (English title shown)
2015 KSAS Spring Conference (KSAS 2015S), Jeongseon, Korea, Apr. 2015
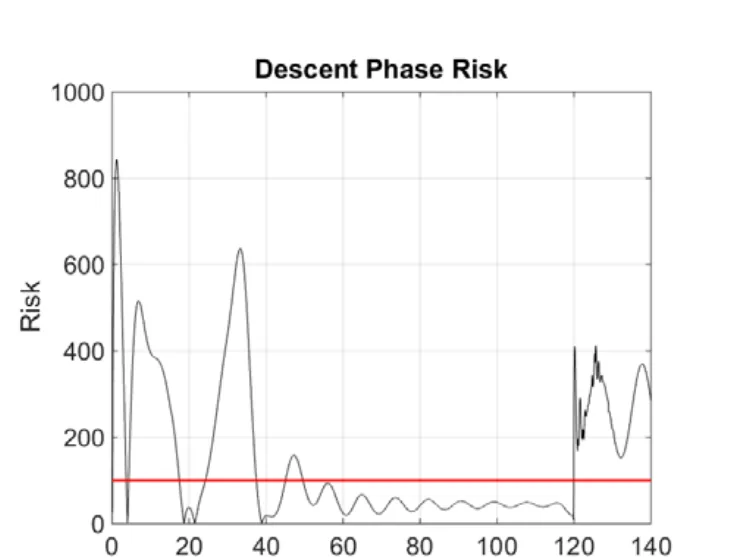
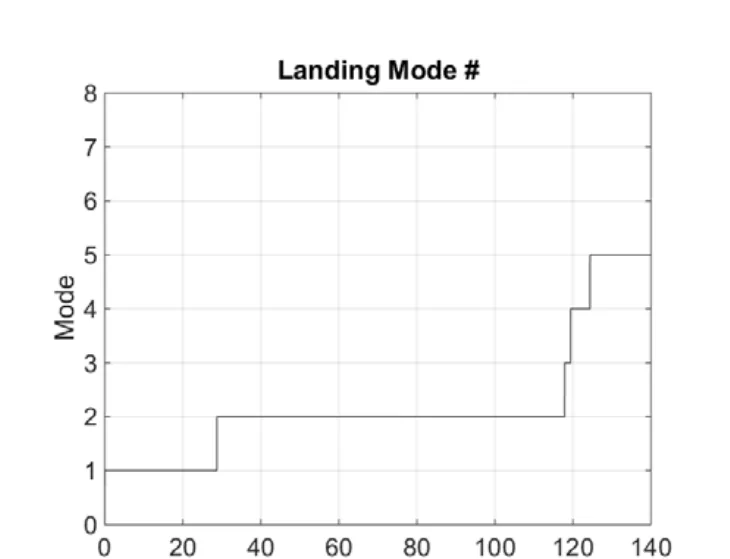
Figures and captions reproduced from the paper (© the authors and original publisher).
Aircraft carrier environment requires a self-determining decision making (DM) process associated with carrier landing for the effective operation of UAVs. In this paper, a DM process for UAV automatic carrier landing (ACL) is proposed, and an ACL sequence for UAVs is established based on that of manned aircraft. The sequence consists of three different phases; approach, descent and touchdown phase. During the descent phase, the UAV takes wave-off (WO) maneuver when specific condition on aircraft position error is not satisfied. Bolter maneuver is executed considering whether or not the arresting hook of the landing aircraft engaged one of four deck pendants. Transition conditions between each phases are studied and numerical simulation is performed to demonstrate the performance of the proposed DM structure.
https://www.dbpia.co.kr/journal/articleDetail?nodeId=NODE06591215BibTeX@inproceedings{Lee2015,
title = {A Decision Making Technique for UAV Automatic Carrier Landing System},
author = {Jihoon Lee and Seokwon Lee and Jungha Park and Youdan Kim and Seungkeun Kim and Jinyoung Suk},
year = {2015},
booktitle = {2015 KSAS Spring Conference (KSAS 2015S), Jeongseon, Korea, Apr. 2015},
note = {Original Korean title: 무인기 자동착함 시스템을 위한 의사결정 기법},
}