Sliding mode guidance and control for UAV carrier landing
IEEE Transactions on Aerospace and Electronic Systems, Vol. 55, No. 2, pp. 951-966, 2019 · 87 citations
Figures and captions reproduced from the paper (© the authors and original publisher).
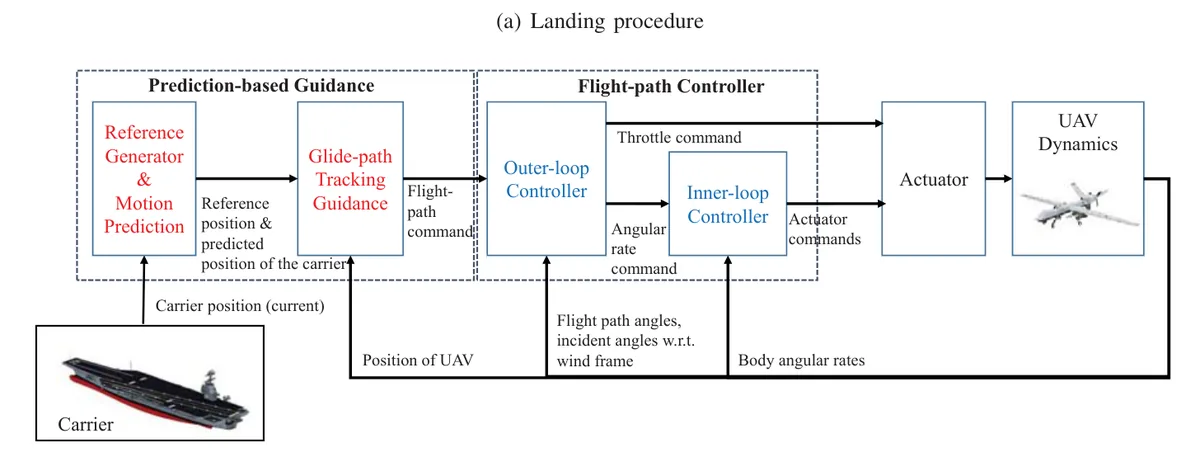
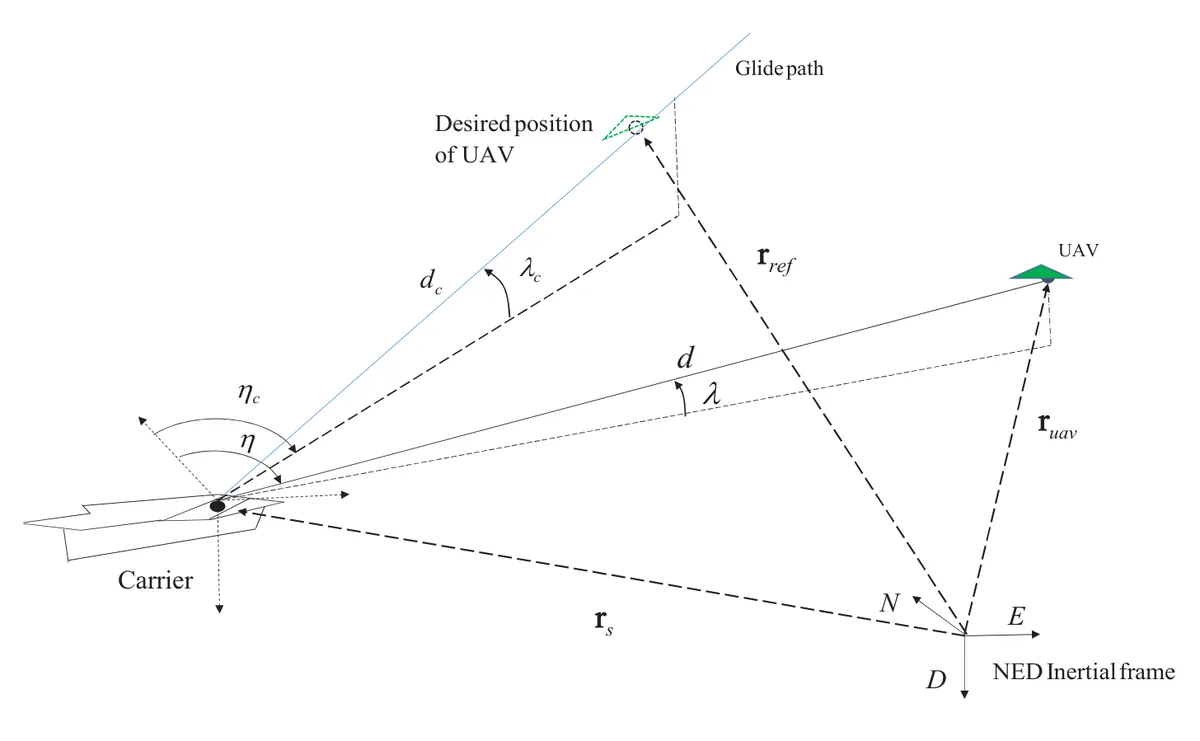
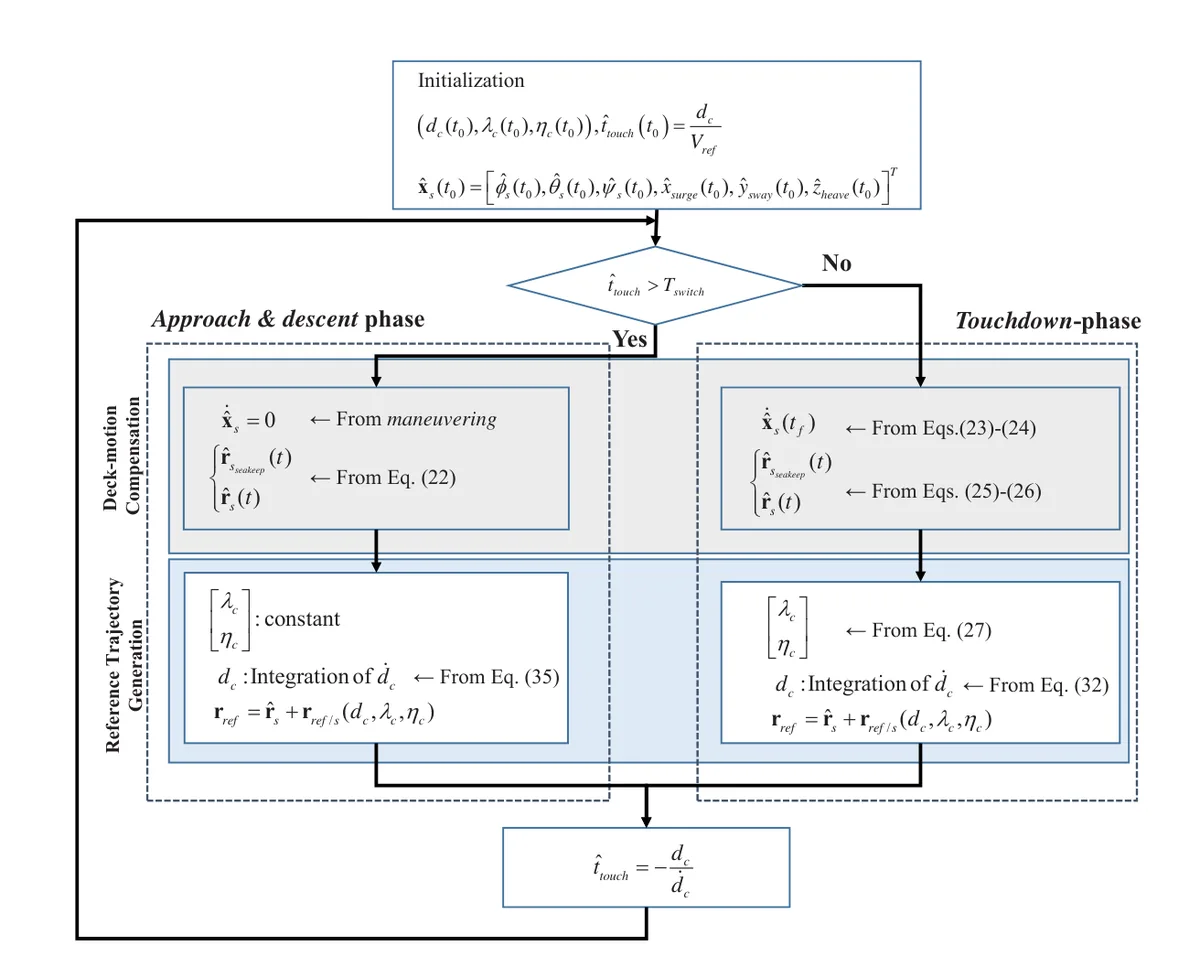
A guidance and control system is proposed for automatic carrier landing of an unmanned aerial vehicle (UAV). To this end, the position and attitude of the carrier is predicted by considering the sea state so that the UAV guidance loop can be compensated during the final approach phase. The landing kinematics and reference trajectory are determined using the predicted touchdown position. Nonlinear guidance and control laws are designed based on a sliding-mode control scheme to make the UAV robustly follow the reference trajectory.
IEEE Xplore
https://ieeexplore.ieee.org/document/8447257/DOI: 10.1109/TAES.2018.2867259https://doi.org/10.1109/TAES.2018.2867259BibTeX@article{Lee2019,
title = {Sliding mode guidance and control for UAV carrier landing},
author = {Seokwon Lee and Jihoon Lee and Somang Lee and Hyunjin Choi and Youdan Kim and Seungkeun Kim and Jinyoung Suk},
year = {2019},
journal = {IEEE Transactions on Aerospace and Electronic Systems},
volume = {55},
number = {2},
pages = {951-966},
doi = {10.1109/TAES.2018.2867259},
}