Flight control of asymmetric variable-span morphing aircraft using nonlinear dynamic inversion
11th Asia-Pacific International Symposium on Aerospace Technology (APISAT), Gold Coast, Australia, Dec. 2019
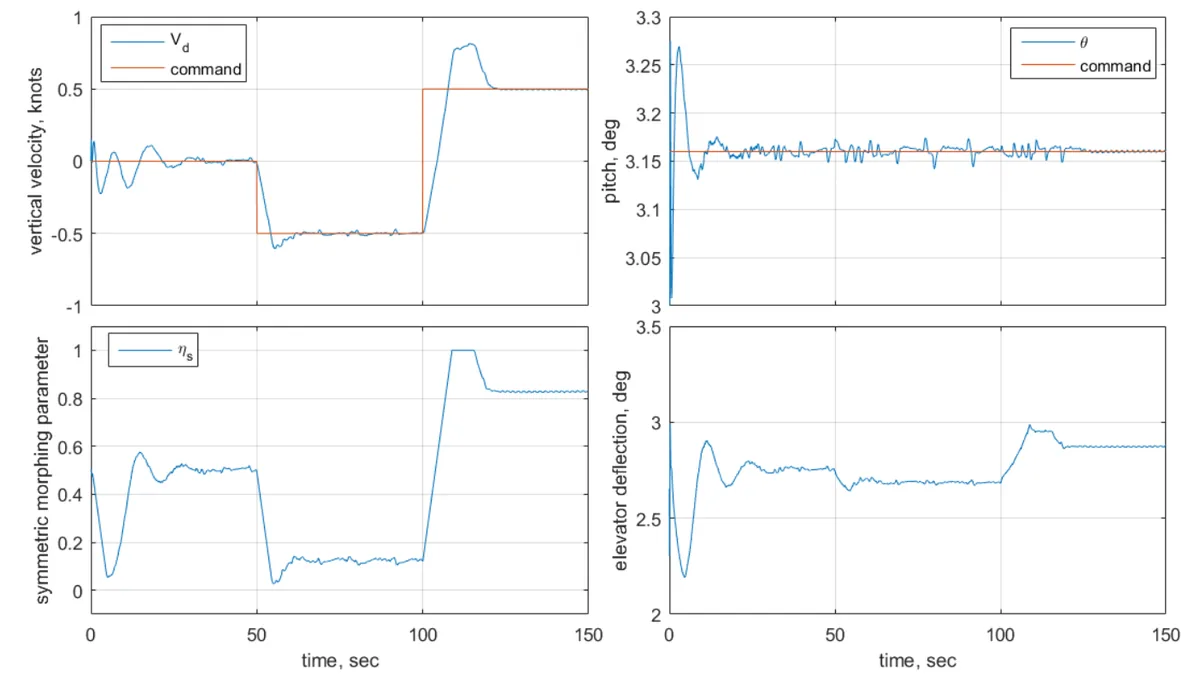
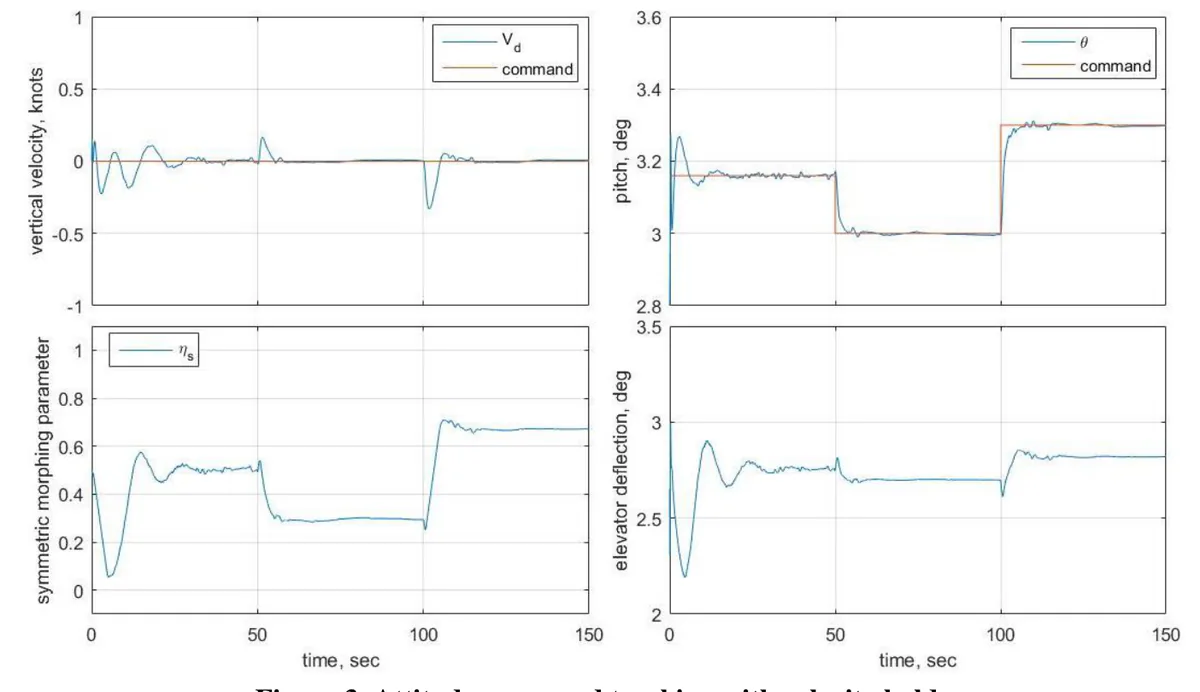
Figures and captions reproduced from the paper (© the authors and original publisher).
A cascade flight control system based on nonlinear dynamic inversion and time-scale separation is proposed for variable-span morphing aircraft. An asymmetric morphing aircraft model is developed by using an experimentally obtained damaged aircraft model. The aircraft is assumed to be able to adjust semi-span of the wing individually, and the resulting changes in the mass and aerodynamic properties due to the morphing are modeled. A set of inversion-based controllers is designed, where symmetric and asymmetric morphing variables are considered as additional control inputs. It is shown that the vehicle is capable of performing unusual maneuvers by using the conventional and morphing surfaces simultaneously. The effectiveness of the proposed scheme is demonstrated by numerical simulation.
https://search.informit.org/doi/10.3316/informit.942442757619423BibTeX@inproceedings{Lee2019,
title = {Flight control of asymmetric variable-span morphing aircraft using nonlinear dynamic inversion},
author = {Jihoon Lee and Seungyun Jung and Seong-hun Kim and Hanna Lee and Youdan Kim},
year = {2019},
booktitle = {11th Asia-Pacific International Symposium on Aerospace Technology (APISAT), Gold Coast, Australia, Dec. 2019},
}