Disturbance observer-based pitch autopilot for morphing UAV during transition phase
AIAA SciTech 2020 Forum, Orlando, FL, USA, Jan. 2020 · 5 citations
Figures and captions reproduced from the paper (© the authors and original publisher).
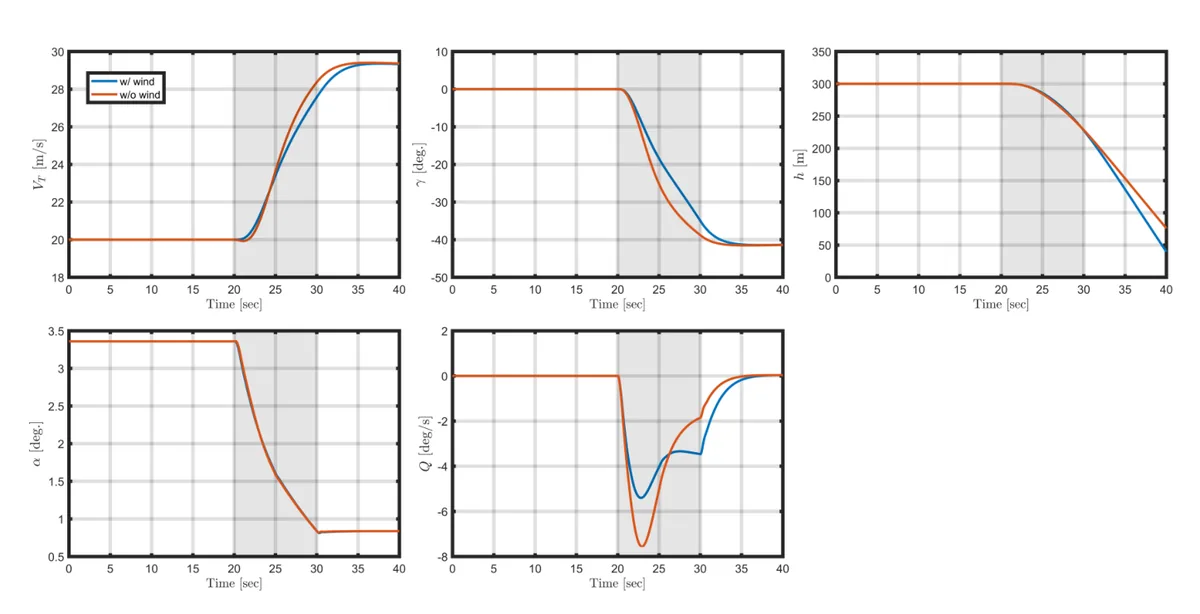
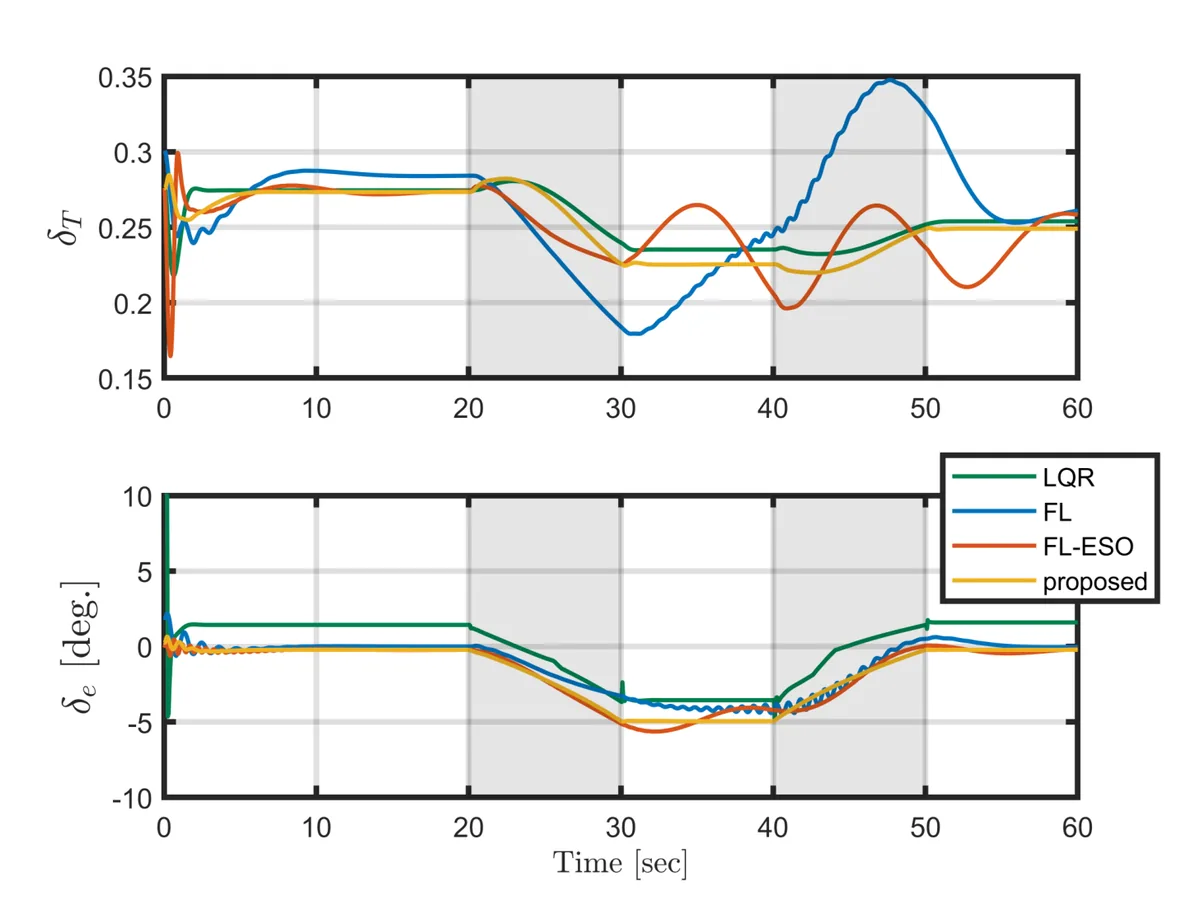
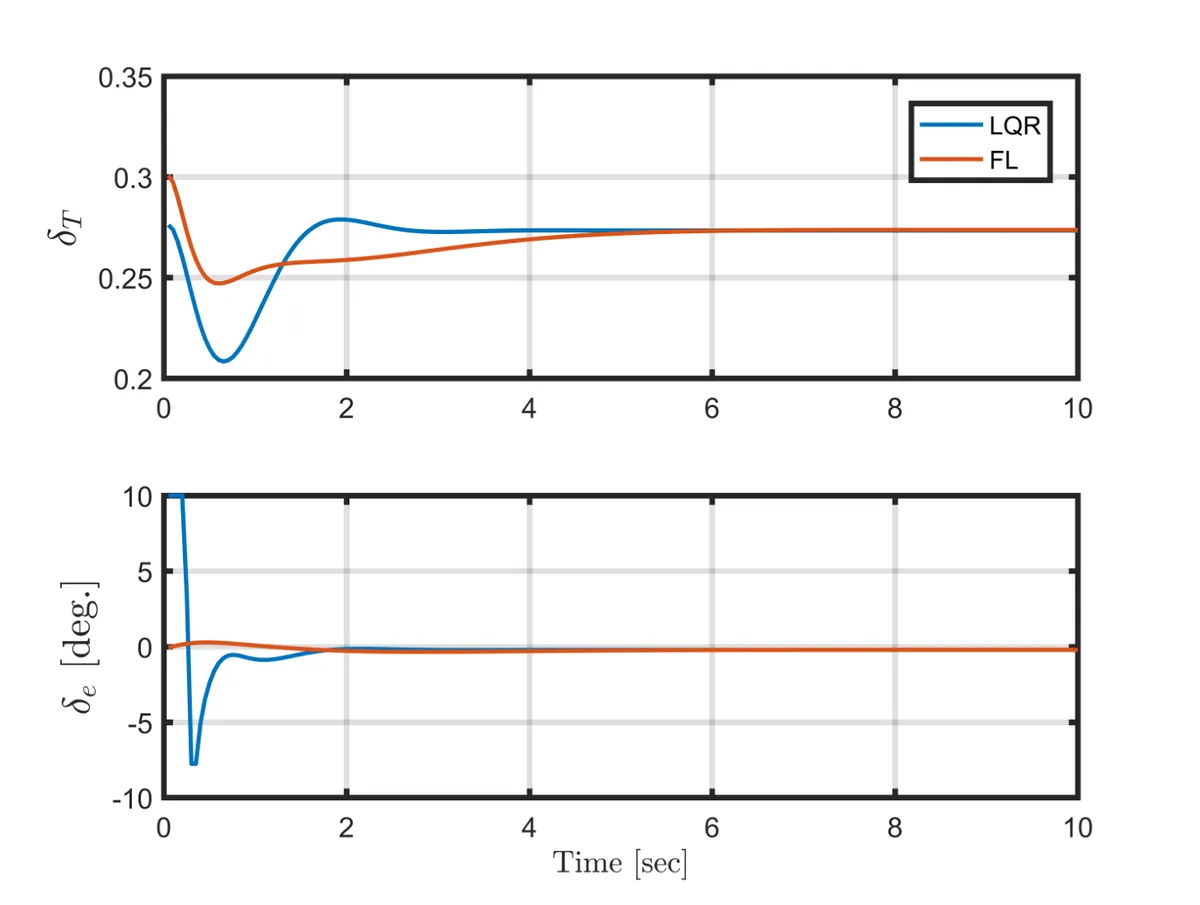
A robust pitch autopilot design scheme is proposed for a morphing unmanned aerial vehicle. Autopilot during wing transition phase is designed considering the properties of system change with time. To maintain the uniform characteristics of the closed-loop system, input-output pseudo-linearization scheme is adopted. Moreover, a novel coordinate transformation is proposed so that the system satisfies the matching condition after the coordinate transformation. Extended state observer is designed to recover flight control performance even in uncertain environment. Numerical simulation demonstrates the effectiveness of the proposed controller during the wing transition phase.
https://arc.aiaa.org/doi/10.2514/6.2020-1087DOI: 10.2514/6.2020-1087https://doi.org/10.2514/6.2020-1087BibTeX@inproceedings{Jung2020,
title = {Disturbance observer-based pitch autopilot for morphing UAV during transition phase},
author = {Seungyun Jung and Jihoon Lee and Seong-hun Kim and Hanna Lee and Youdan Kim},
year = {2020},
booktitle = {AIAA SciTech 2020 Forum, Orlando, FL, USA, Jan. 2020},
doi = {10.2514/6.2020-1087},
}